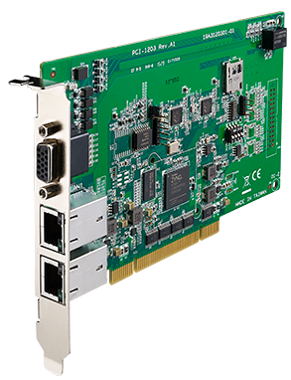
For the EtherCAT motion port, the cycle time is no more than 500 µs for connecting up to 32 servo motor axes. For fast I/O tasks, the cycle time is a maximum of 200 µs in high-speed applications. The PCI-1203 features four channels for isolated digital outputs and eight channels for isolated digital inputs, thus meeting the high-precision requirements of real-time applications. The PCI-1203 is compatible with the Common Motion API, a simplified programming interface with a graphical user interface.
The new PCI-1203 offers a solution for reducing downtime and upgrades, as the application code requires only minor adjustments for use with Advantech SoftMotion drivers. To this end, user-friendly examples are provided to minimize programming effort and simplify configuration and diagnostics.
To meet the demanding real-time requirements of the master, the slave EtherCAT requires specialized hardware. Therefore, the protocol is integrated into various controllers or ASIC solutions, such as IP hardware.