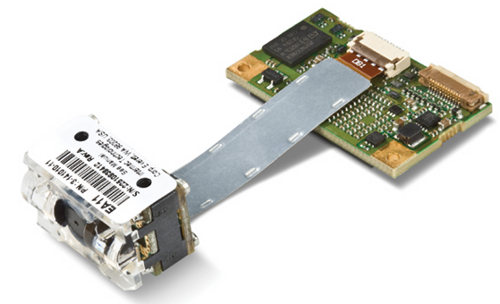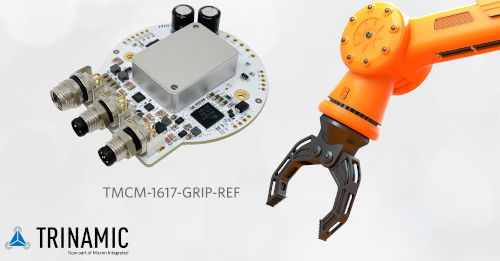
The reference design incorporates Maxim Integrated's high-precision configurable analog input/output MAX22000 and MAX14906 four-channel digital input/output to adjust the multiple modes of the Trinamic TMCM-1617 single-axis servo controller.
The TMCM-1617-GRIP-REF reference design, designed to fit the standard form factor used for EoAT grippers, supports EtherCAT, IO-Link, or RS-485 industrial communication, provides software-programmable analog and digital inputs/outputs, and can be configured using the Trinamic Motion Control Language (TMCL-IDE) integrated development environment. This combination of reference design and software platform offers design engineers a simple way to quickly deliver a complete EoAT solution.
Key Benefits
- Accelerated Time to Market: The open-source EoAT gripper reference design is a fully integrated, intelligent hardware platform that provides motor control algorithms and protocol stacks to cut end-of-arm tooling development time in half.
- Reduced Size: The reference design integrates hardware-based FOC, software-configurable I/Os, and three communication protocol stacks into a compact 4,197 mm² solution.
- Increased Productivity: Real-time adjustment of the TMCM-1617's various servo drive modes, including gripper position and gripping force, enhances flexibility for increased throughput on the factory floor.