




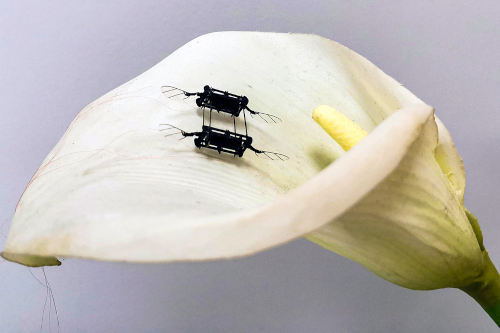
Now, these researchers have pioneered a manufacturing technique that allows them to build soft actuators that operate at 75 percent less voltage than current versions, while carrying 80 percent more payload. These soft actuators are like artificial muscles that rapidly flap the robot's wings.
This new manufacturing technique produces artificial muscles with fewer defects, which significantly extends the lifespan of the components and increases the robot's performance and payload.
"This opens up many opportunities for us in the future to move towards putting power electronics into the microrobot. People tend to think that soft robots aren't as capable as rigid robots. We demonstrated that this robot, which weighs less than a gram, is the longest-flying robot with the least error during hovering. The takeaway message is that soft robots can outperform rigid robots," says Kevin Chen, the D. Reid Weedon, Jr. '41 Assistant Professor in the Department of Electrical Engineering and Computer Science, head of the Soft and Micro Robotics Lab at the Research Electronics Laboratory (RLE), and senior author of the paper.
Chen's co-authors are Zhijian Ren and Suhan Kim, co-senior authors and graduate students at EECS; Xiang Ji, a research scientist at EECS; Weikun Zhu, a chemical engineering graduate student; Farnaz Niroui, an assistant professor at EECS; and Jing Kong, a professor at EECS and a principal investigator at RLE. The research has been accepted for publication in Advanced Materials and is included in the journal's Rising Stars series, which recognizes outstanding work by early-career researchers.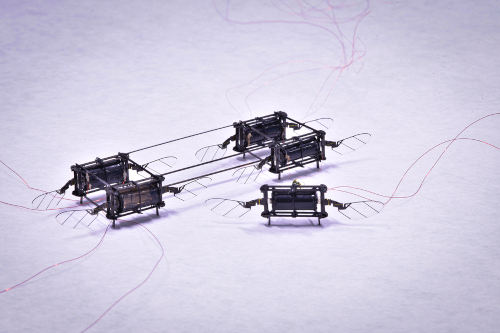
Build muscles
The rectangular microrobot, which weighs less than a quarter of a penny, has four sets of wings, each powered by a soft actuator. These muscle-like actuators are made of layers of elastomer sandwiched between two very thin electrodes and then rolled into a soft cylinder. When a voltage is applied to the actuator, the electrodes compress the elastomer, and that mechanical tension is used to flap the wing.
The larger the surface area of the actuator, the less tension is needed. Thus, Chen and his team build these artificial muscles by alternating between as many ultrathin layers of elastomer and electrodes as possible. As the elastomer layers become thinner, they become more unstable.
For the first time, researchers have created an actuator with 20 layers, each 10 micrometers thick (roughly the diameter of a red blood cell). But they had to reinvent parts of the manufacturing process to achieve this.
One of the main obstacles was the spin coating process. During spin coating, an elastomer is poured onto a flat surface and spun rapidly, and the centrifugal force pulls the film outward to make it thinner.
"In this process, air re-enters the elastomer and creates many microscopic air bubbles. The diameter of these air bubbles is only about one micrometer, so we used to ignore them. But as the layers become thinner, the effect of the air bubbles becomes stronger. That's why it hasn't traditionally been possible to make these layers so thin," Chen explains.
He and his colleagues discovered that if they perform a vacuuming process immediately after rotational coating, while the elastomer is still wet, the air bubbles are eliminated. Then, they bake the elastomer to dry it.
Eliminating these defects increases the actuator's power by more than 300% and significantly improves its lifespan, Chen says.
The researchers also optimized the thin electrodes, which are made of carbon nanotubes—super-strong coils of carbon about 1/50,000th the diameter of a human hair. A higher concentration of carbon nanotubes increases the actuator's power and reduces the voltage, but denser layers also contain more defects.
For example, carbon nanotubes have sharp ends and can pierce the elastomer, causing a short circuit in the device, Chen explains. After much trial and error, the researchers found the optimal concentration.
Another problem arises during the curing phase: as more layers are added, the actuator takes longer and longer to dry.
"The first time I asked my student to make a multi-layer actuator, once he got to 12 layers, he had to wait two days for it to cure. That's totally unsustainable, especially if you want to scale up to more layers," Chen says.
They discovered that baking each layer for a few minutes immediately after transferring the carbon nanotubes to the elastomer reduces the curing time as more layers are added.
Best-in-class performance
After using this technique to create a 20-layer artificial muscle, they tested it against their previous six-layer version and the latest generation of rigid actuators.
During the takeoff experiments, the 20-layer actuator, which requires less than 500 volts to operate, exerted enough power for the robot to have a lift-to-weight ratio of 3.7 to 1, so it was able to carry objects nearly three times its weight.
They also demonstrated a 20-second hover, which, according to Chen, is the longest ever recorded by a subgroup robot. Their hovering robot maintained its position more stably than any of the others. The 20-layer actuator continued to function flawlessly after being driven for more than 2 million cycles, far exceeding the lifespan of other actuators.
"Two years ago, we created the most power-dense actuator, and it could barely fly. We started wondering if soft robots could ever compete with rigid ones. We observed one defect after another, so we kept working and solved one manufacturing problem after another, and now the performance of soft actuators is catching up. They're even a little better than the latest generation of rigid ones. And there are still a number of manufacturing processes in materials science that we don't understand. So I'm very excited to continue reducing actuation stress," he says.
Chen hopes to collaborate with Niroui to build actuators in a cleanroom at MIT.nano and leverage nanofabrication techniques. Currently, his team is limited by layer thickness due to airborne dust and the maximum coating speed. Working in a cleanroom eliminates this problem and would allow them to use methods, such as doctor blading, that are more precise than spin coating.
Although Chen is delighted with producing 10-micrometer actuator layers, his hope is to reduce the thickness to just 1 micrometer, which would open the door to many applications for these insect-sized robots.
This work is supported, in part, by the MIT Electronics Research Laboratory and a Mathworks graduate fellowship.
###
Written by Adam Zewe, MIT News Office













