




Sub-terahertz wavelengths, which lie between microwave and infrared radiation on the electromagnetic spectrum, can be easily detected through fog and dust clouds, whereas infrared-based LiDAR imaging systems used in autonomous vehicles fail to detect them. To detect objects, a sub-terahertz imaging system sends an initial signal through a transmitter; a receiver measures the absorption and reflection of the bounced sub-terahertz wavelengths. This sends a signal to a processor that recreates an image of the object.
But implementing sub-terahertz sensors in autonomous vehicles is challenging. Sensitive and accurate object recognition requires a strong baseband output signal from the receiver to the processor. Traditional systems, made of discrete components that produce such signals, are large and expensive. Smaller on-chip sensor arrays exist, but they produce weak signals.
In an article published online on February 9 by the IEEE Journal of Solid-State Circuits, researchers describe an on-chip bidirectional sub-terahertz receiving array that is orders of magnitude more sensitive, meaning it can better capture and interpret sub-terhertz wavelengths in the presence of a large amount of signal noise.
To achieve this, they implemented a scheme of independent signal-mixing pixels, called "heterodyne detectors," which are typically very difficult to integrate densely onto chips. The researchers drastically reduced the size of the heterodyne detectors so that many of them could fit on a single chip. The trick was to create a compact, multipurpose component that could simultaneously mix input signals, synchronize the pixel array, and produce strong output baseband signals.
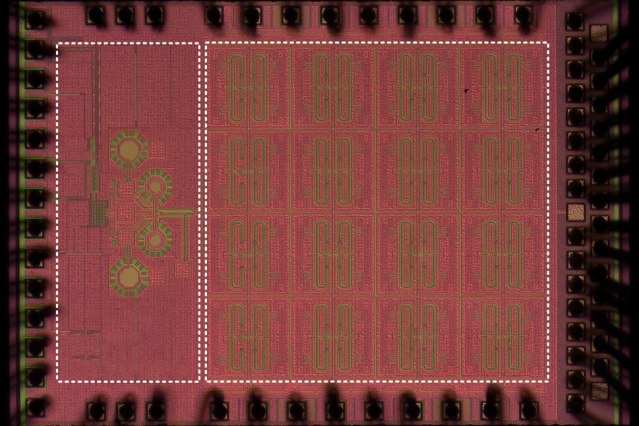
The researchers built a prototype with a 32-pixel array integrated into a 1.2-square-millimeter device. These pixels are approximately 4,300 times more sensitive than those in today's best on-chip sub-terahertz array sensors. With further development, the chip could potentially be used in driverless vehicles and autonomous robots.
"A major motivation for this work is to have better 'electric eyes' for autonomous vehicles and drones," says co-author Ruonan Han, associate professor of electrical engineering and computer science and director of the Terahertz Integrated Electronics Group at MTL (MIT Microsystems Technology Laboratories). "Our low-cost, on-chip sub-terahertz sensors will play a complementary role to LiDAR when the environment is hazardous.".
Along with Han on the article are first author Zhi Hu and co-author Cheng Wang, both doctoral students in the Department of Electrical Engineering and Computer Science who work in Han's research group.
Decentralized Design:
The key to the design is what the researchers call "decentralization." In this design, a single pixel, called a "heterodyne" pixel, generates the rhythm frequency (the frequency difference between two incoming sub-terahertz signals) and the "local oscillation," an electrical signal that changes the frequency of an input signal. This "down-mixing" process produces a signal in the megahertz range that can be easily interpreted by a baseband processor.
The output signal can be used to calculate the distance to objects, similar to how LiDAR calculates the time it takes for a laser to hit an object and bounce back. Furthermore, combining the output signals from a pixel array with the pixels' orientation in a specific direction can enable high-resolution imaging of a scene. This allows not only object detection but also recognition, which is crucial for autonomous vehicles and robots.
Heterodyne pixel arrays only work when the local oscillation signals of all pixels are synchronized, which means a signal synchronization technique is required. Centralized designs include a single hub that shares local oscillation signals with all pixels.
These designs are typically used by lower-frequency receivers and can cause problems in sub-terahertz frequency bands, where generating a high-power signal from a single concentrator is notoriously difficult. As the array size increases, the power shared by each pixel decreases, reducing the strength of the output baseband signal, which is highly dependent on the power of the local oscillation signal. As a result, a signal generated by each pixel can be very weak, leading to low sensitivity. Some on-chip sensors have begun using this design, but they are limited to eight pixels.
The researchers' decentralized design addresses this sensitivity-to-scale trade-off. Each pixel generates its own local oscillation signal, used to receive and mix the incoming signal. Furthermore, an integrated coupler synchronizes its local oscillation signal with that of its neighbor. This gives each pixel more output power, since the local oscillation signal does not flow from a global center.
A good analogy for the new decentralized design is an irrigation system, Han says. A traditional irrigation system has a pump that directs a powerful flow of water through a network of pipes that distribute water to many sprinkler sites. Each sprinkler sprays water at a much weaker flow than the initial flow from the pump. If you want the sprinklers to pulse at the same frequency, that would require another control system.
The researchers' design, on the other hand, gives each site its own water pump, eliminating the need for connecting pipes, and provides each sprinkler with its own powerful water output. Each sprinkler also communicates with its neighbor to synchronize their pulses. "With our design, there's essentially no limit to scalability," Han says. "You can have as many sites as you want, and each site still pumps the same amount of water... and all the pumps work together.".
However, the new architecture potentially makes the footprint of each pixel much larger, posing a significant challenge for large-scale, high-density array integration. In their design, the researchers combined several functions from four traditionally separate components (antenna, downmixer, oscillator, and coupler) into a single "multitasking" component assigned to each pixel. This enables a decentralized 32-pixel design.
"We designed a multifunctional component for a [decentralized] on-chip design and combined some discrete structures to reduce the size of each pixel," says Hu. "Even though each pixel performs complex operations, it maintains its compactness, so we can still have a large-scale, dense array.".
Frequency-guided:
In order for the system to measure the distance to an object, the frequency of the local oscillation signal must be stable.
To that end, the researchers incorporated a component called a phase-locked loop into their chip, which locks the sub-terahertz frequency of the 32 local oscillation signals to a stable, low-frequency reference. Because the pixels are coupled, their local oscillation signals share an identical and highly stable phase and frequency. This ensures that meaningful information can be extracted from the output baseband signals. This entire architecture minimizes signal loss and maximizes control.
"In summary, we achieved a coherent array, while at the same time having a very high local oscillation power for each pixel, so each pixel achieves high sensitivity," Hu comments.
###
Written by Rob Matheson, MIT News Office













